
RoboticsResearch brief
A robot needs more than a destination. It needs a safe way there.
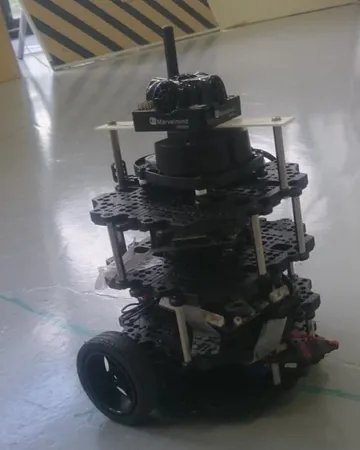
MIT's SANDO planner tackles moving obstacles in unmapped spaces. The interesting part is the boundary of its safety guarantee.
Follow the sensing, estimation, planning and control loop before evaluating a robot demonstration.
A robot must keep updating its estimate of the world while choosing and controlling motion.
Read the illustrated explanation →MIT's SANDO planner tackles moving obstacles in unmapped spaces. The interesting part is the boundary of its safety guarantee.